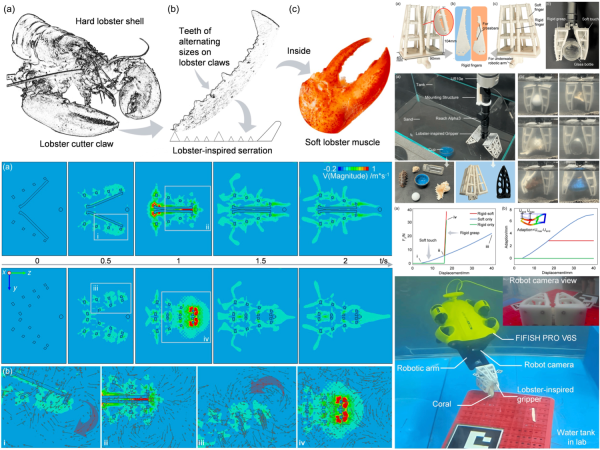
Bio-inspired Rigid–Soft Interaction for Robust Picking Underwater
Ocean Engineering, 346: 123774, 2026
I am a Ph.D. student at SUSTech, advised by Fang Wan and Chaoyang Song. I received my B.E. in Mechanical Engineering from SUSTech in 2022 and spent time at AncoraSpring in 2025.
My research spans robotic perception and learning, from dexterous manipulation and humanoid whole-body control to tactile sensing and vision-based deformation perception in soft robots. I aim to develop adaptive robots that perceive, understand, and interact with the physical world through vision, touch, and motion.
# Equal contribution · * Corresponding author
Ocean Engineering, 346: 123774, 2026
IEEE Robotics and Automation Practice, 2025
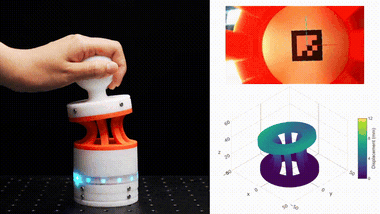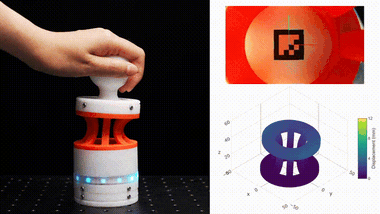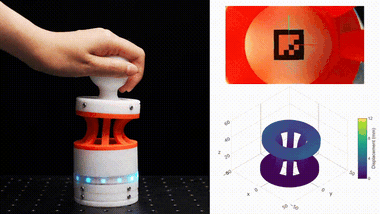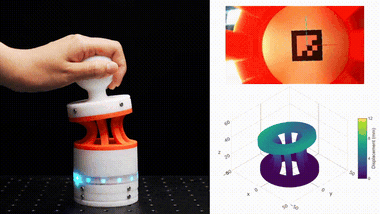
Advanced Intelligent Systems, 2500444, 2025
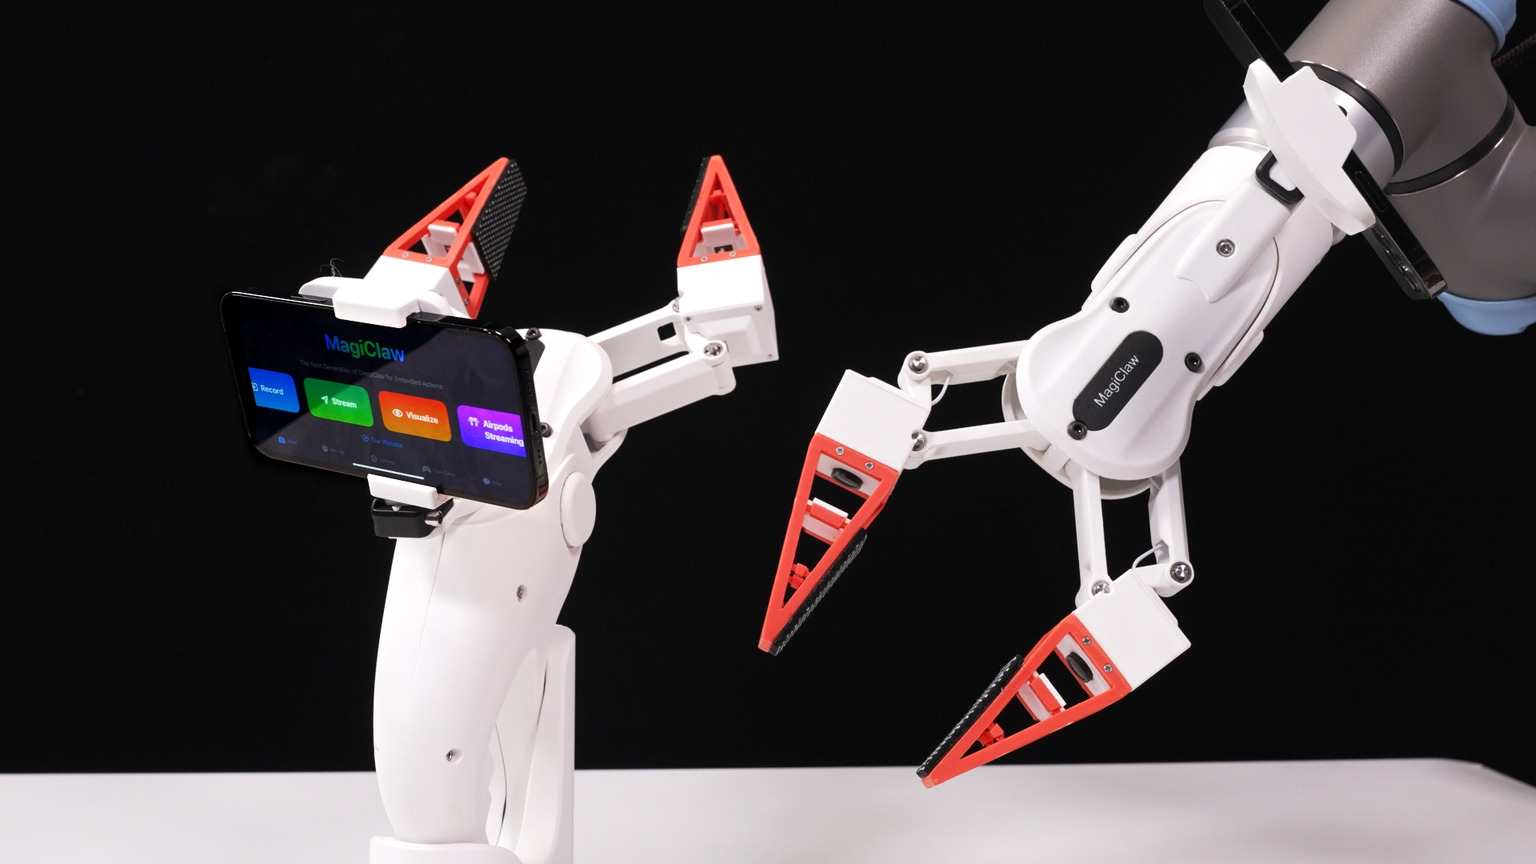
IEEE Transactions on Robotics, 40: 4684-4698, 2024
Measurement, 238: 115376, 2024
The International Journal of Robotics Research, 43(12): 1916-1935, 2024
Materials & Design, 238: 112629, 2024
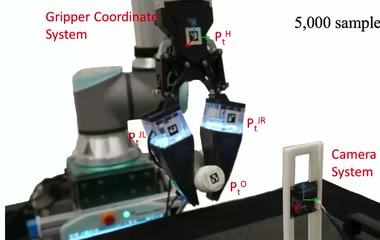
Biomimetics, 8(6):501, 2023
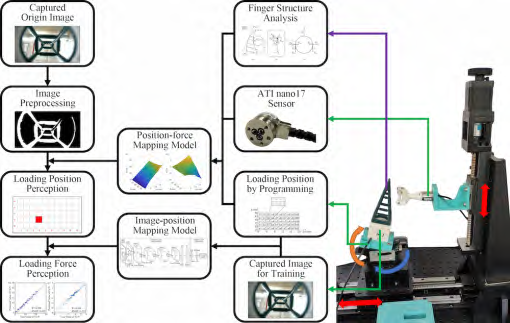
Frontiers in Robotics and AI, 8:787187, 2021
IEEE Robotics and Automation Letters, 6(2):3817-3824, 2021
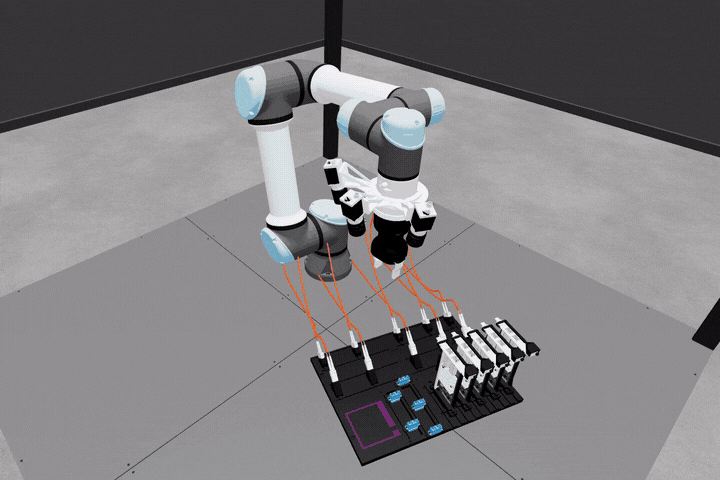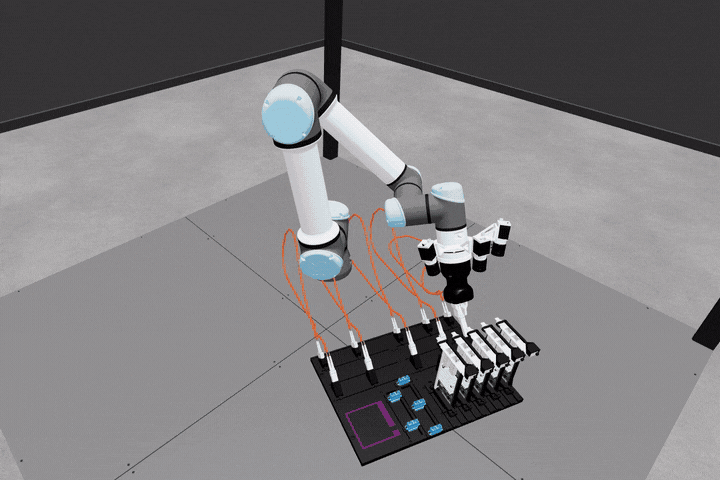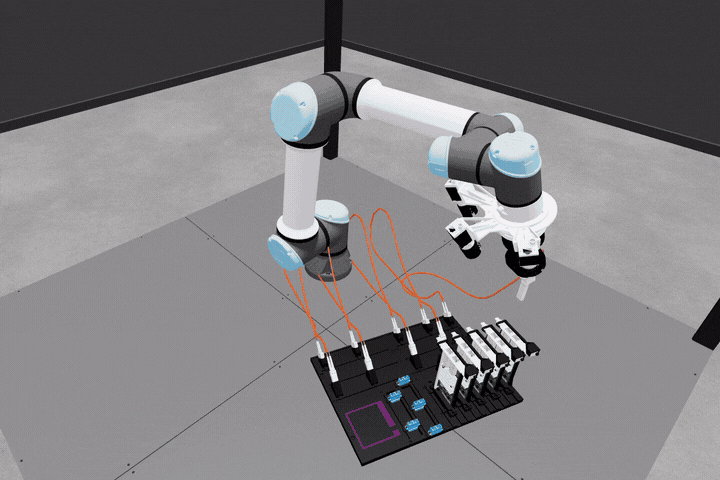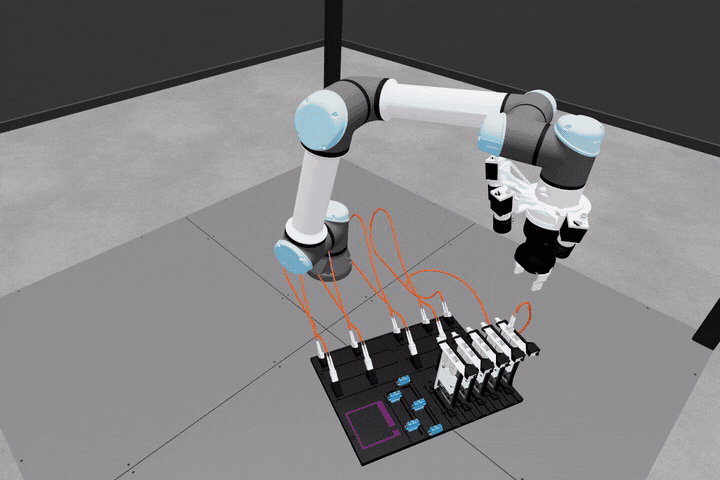
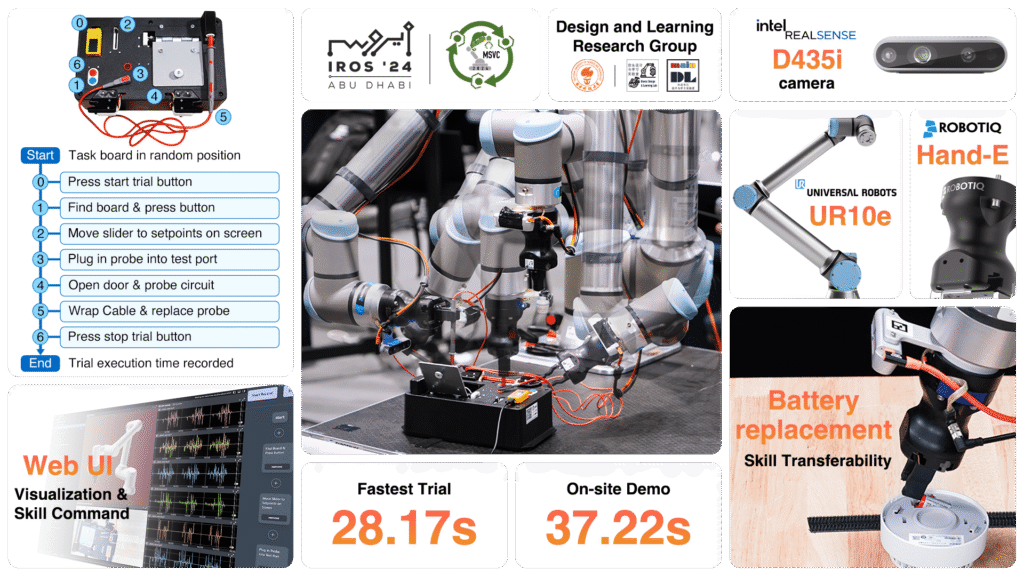
Vision- and force-guided robotic cable manipulation and insertion. Our team ranked 9th in the qualification phase.
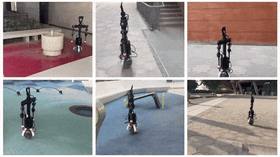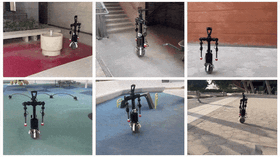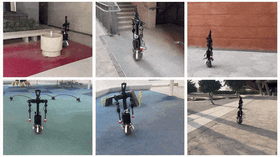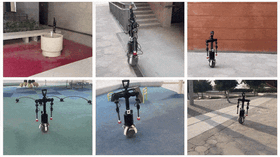
A humanoid ballbot with reinforcement-learned locomotion transferred from simulation to hardware.
An open-source soft gripper for transferring human demonstrations to robotic manipulation.
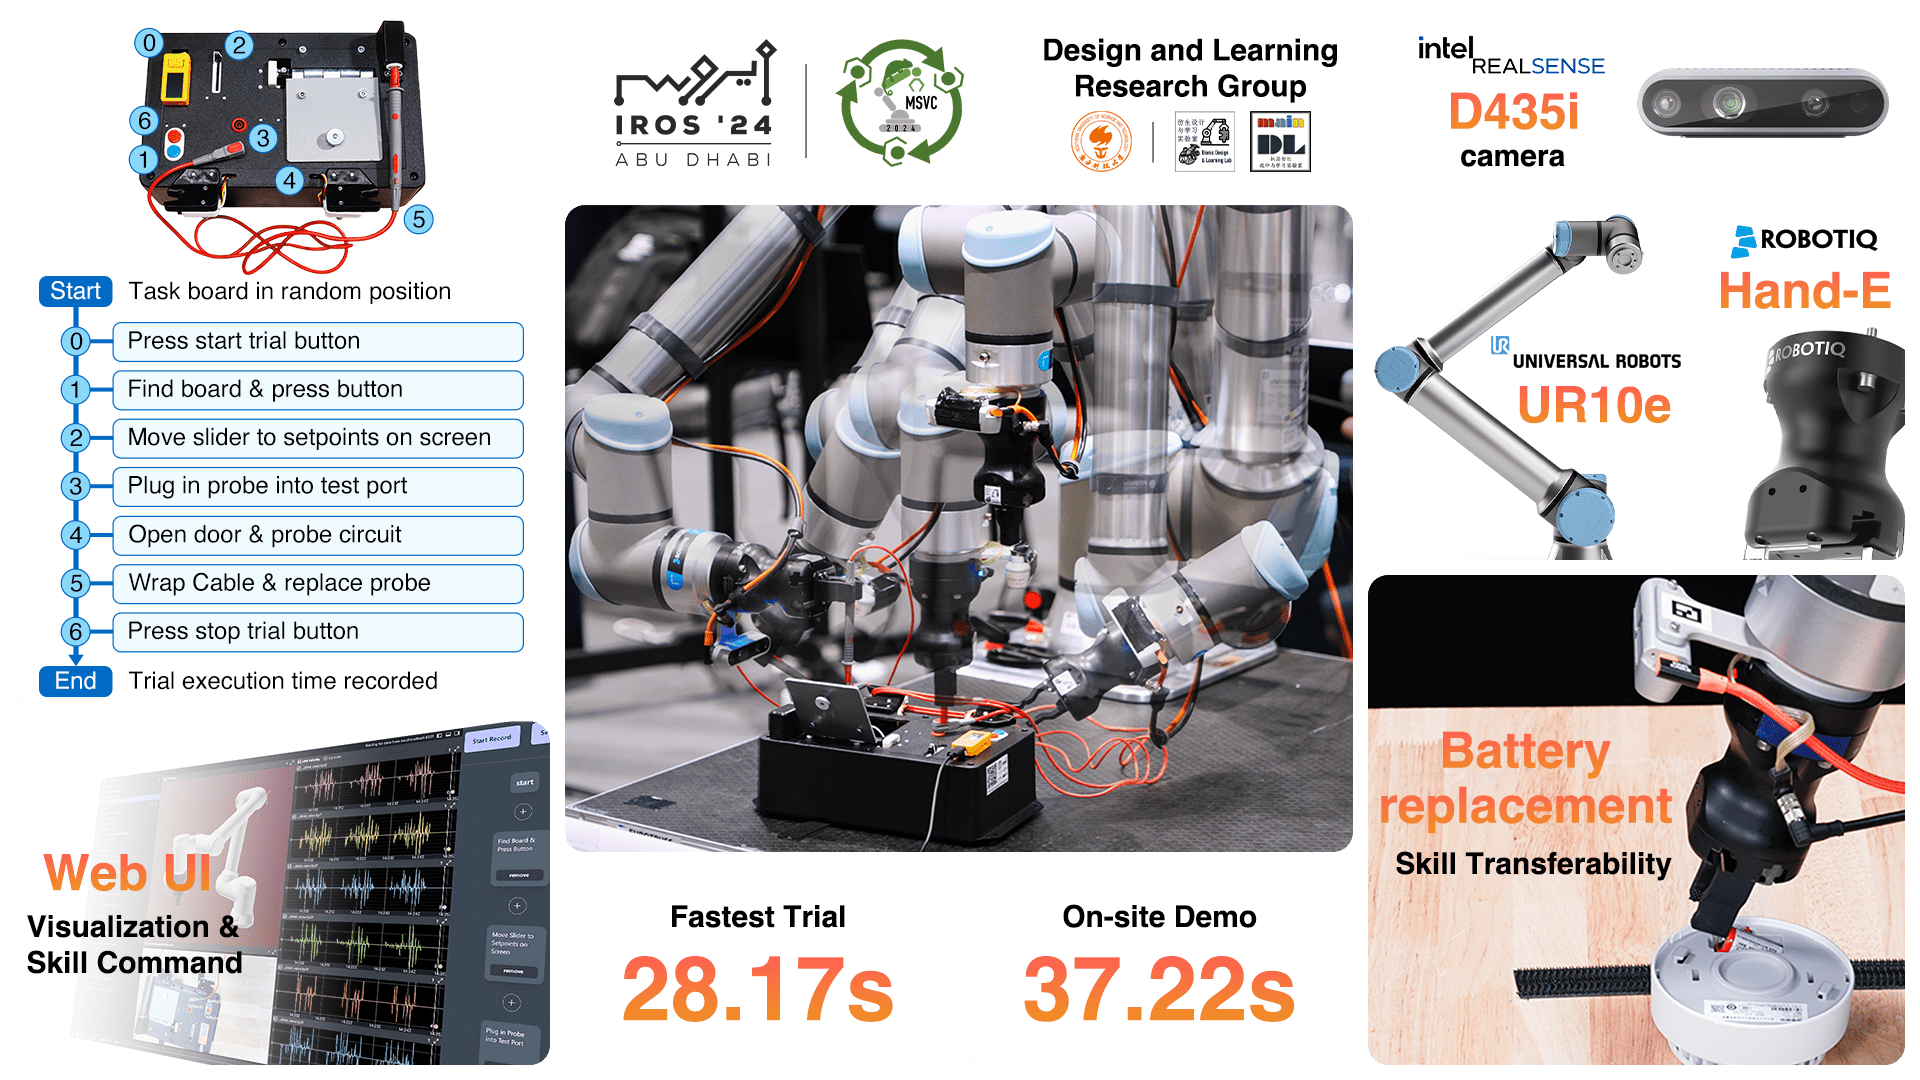
A reusable robot skill system for the IROS 2024 task board challenge, awarded the Fastest Task Board Solution.